Beauty is often simple ideas that can have complex and widely applicable results. I believe this subject is one such example. A third of this post is intended to be understandable to anyone that is interested. My engineering colleagues may find this annoyingly basic, but, revisiting the basics is not necessarily a bad thing.
Imagine a fictional particle that has no mass, suspended in the vacuum of space. Such a particle has no inertia (requires no energy to get it moving), no friction or resistance against anything (nothing to prevent it from moving) and is not connected to anything that will pull it back to its original location. If we apply even the tiniest force, it will shoot away infinitely far in an infinitesimal short period of time. There is nothing governing its motion.
The same force step applied to a completely ungoverned particle — no stiffness, no damping, no mass. The instant the force is applied the position shoots to infinity and stays there. With no restoring force and no resistance, there is nothing to bring it back.
Governing Interactions
Figure show how the ungoverned particle, not only moved instantly infinitely far (the arrow pointing to infinity), it also instantly moved at an infinite velocity (vertical lines), as well as instantly had an infinite acceleration (the sharp bent) as long as the force acted upon it. Fortunately all matter has mass, making it lazy to change a state of stasis or motion.
The mass, or more generally referred to as inertia makes the bends rounder as listed in Table. Additionally friction is all around us, dissipating kinetic energy into everything moving objects touches. It limits the speed that can be reached, reducing the gradient. But forces that strive to reduce displacement will be the starting consideration.
| Constraint | Caused by | Presented as |
|---|---|---|
| Displacement | Connection between bodies | Limited displacement |
| Velocity | Friction, Damping | Limited gradient |
| Acceleration | Mass, Inertia | Round corners |
Table of governing effects and how it's presented on a displacement graph.
Note
This article is only concerned with macroscopic physical phenomena where bodies move relatively slow (compared to light). The fictitious infinities of position, velocity and acceleration in the imaginary absence of governing interactions is the important takeaway.
Displacement Constraints
A car driving on a level freeway has no direct displacement constraint relative to an earlier location. It can stop and freely remain anywhere on the freeway. It has, what is called, rigid body motion. When pulling a trailer, the car and trailer can be approximated as lumped masses connected by a stiff spring. Both, together, still exhibit rigid body motion but relative displacement between them is resisted. When accelerating and decelerating, the trailer coupler (and surrounding structure) will slightly stretch and compress respectively.
There are different types of displacement constraints. The car body and wheels can also be approximated as lumped masses connected by softer springs (suspension). Zooming in on one part like a chassis beam, it can be approximated by a thousand slices connected by springs. Even the car on a slope, free to roll, will be pulled to a lower point. Similar to a pendulum, this is also a form of distance constraint. Here gravity acts as the displacement constraining force that drops to zero at the lowest point.
The Figure particle’s displacement will become limited when connected to a stationary object. Most connected systems, except for example pendulums, can be modeled as lumped bodies joined by flexible members (springs). The assumption is that the stiffness is linear and the spring applies an opposite force that is proportional to the distance moved away from its original location (Hooke’s Law).
\[F = kx\]
This may seem like a very idealistic model of reality but is actually a very good approximation. From your eyeballs to a guitar string, everything can compress and stretch. Even buildings bend and prop shafts twist in the same near linear springy way. The contact point of a marble resting on a sheet of glass deforms both surfaces to create a contact patch, without which the stress would be infinite and crack the glass.
A step-up-down force applied on an object only governed by stiffness. The position responds instantaneously and proportionally, mirroring the form of the force exactly.
Figure shows how applying a force to the particle now will displace it proportional to the force. It instantaneously moves to the equilibrium distance between the acting force and the constraining spring force. The position is now governed but it still reaches infinite speeds and acceleration. The graph still has both the vertical gradient and sharp bents.
Velocity Constrains
The second law of thermodynamics says that entropy always increases. If entropy is defined as the spread of energy one can see how any moving object spreads its kinetic energy to the surroundings. Everything that moves bumps into air molecules or scraps along surfaces. Even rolling ball bearings compress the crystal lattice in their races, absorbing some of the briefly stored potential energy and converting it into heat.
The resistance to motion (or velocity) becomes intuitively more as speed increases. This is called damping, but there are also different types of velocity constraints. Air resistance is a resisting force proportional to velocity squared. Friction force between two surfaces is usually modeled as a constant resisting force. However, for low Reynolds numbers like viscous oil flowing laminarly through an orifice in a damper, the damping resistance force is linearly proportional to velocity.
\[F = cv\]
With only damping applied to the Figure particle, its velocity is limited. Displacement wise, it can still move infinitely far (exhibit rigid body motion) but gets stopped by damping when no force is applied to it. It also still has sharp corners because of the lack of inertia.
A step-up-down force applied on an object only governed by damping. Velocity is proportional to force, so position ramps linearly during the force and holds flat once it is removed — no inertia to carry it further.
Acceleration Constraints
Enough playing around with imaginary massless particles. All matter has mass, and mass brings about very interesting phenomena. It makes objects lazy to get moving or slow down, governing acceleration. This is called inertia and defined with Newton's second law of motion.
\[F = ma\]
Only accounting for mass, the Figure particle acceleration is governed and the position changes quadratically when the force is applied. Notice how the position now keeps on changing after the force is removed with a constant velocity. Without damping it can reach infinite speeds and continue into infinity.
A step-up–down force applied to an object governed only by inertia. Position rises quadratically as the constant acceleration builds velocity. When the force is removed the acceleration drops to zero but the velocity — and therefore the position — carry on indefinitely.
Component Summary
The three components are stiffness, damping and inertia that opposes displacement, velocity and acceleration respectively. It's important to point out that velocity is the rate of change in displacement and acceleration is the rate of change in velocity. Energy is also pulled into the picture as it goes hand-in-hand with the components.
Movement Calculus
| Oppose | |
|---|---|
| Stiffness | Displacement |
| Damping | Velocity → Change in Displacement |
| Inertia | Acceleration → Change in Velocity → Change in change in Displacement |
Governing components and type of movement they oppose.
That is why displacement is the y-value in Figure, velocity is the gradient (rate of change in displacement) and acceleration are bends (how the gradient changes). In calculus the rate of change of a value is a derivative and can be written as:
\[v = \frac{dx}{dt}, \quad a = \frac{dv}{dt} = \frac{d^2x}{dt^2}\]
The stiffness displacement graph is therefore the derivative of the damping displacement graph and the damping graph the derivative of the inertia graph. When looking from a velocity perspective, the damping velocity graph looks the same as the stiffness. The pattern is shown in Figure that shows all nine combinations of components and perspectives. Diagonals stay the same and differentiation is from right to left and top to bottom.
The same step force applied to a particle governed only by stiffness, damping or inertia, seen as position, velocity and acceleration. Each row is the derivative of the row above, so moving down a row looks the same as moving one column to the left. Where a graph jumps, its derivative becomes an infinite spike.
Component Details
- Stiffness
- CausesSpring, material elasticity, air compression, shaft torsion
- OpposesDisplacement
- Function ofdisplacement, \(x\)
- Stores or Dissipates EnergyStores potential energy
- Typical Symbol, Unit\(k\), N/m
- Typical Characteristic\(F = kx\)
| Mechanism | Equation | Parameter | Units |
|---|---|---|---|
| Hooke spring | \(F = kx\) | Stiffness \(k\) | N/m |
| Torsional spring | \(T = k_t \theta\) | Nm/rad | Nm/rad |
| Beam bending | \(F = \frac{3EI}{L^3}x\) | Structural stiffness | N/m |
| Gravity pendulum | \(F \approx mg\frac{x}{L}\) | Gravity stiffness | N/m |
| Gas spring | \(F = P(x)A\) | Pressure stiffness | N/m |
| Magnetic spring | nonlinear \(F(x)\) | Magnetic field | N |
Various mechanisms of stiffness
- Damping
- CausesAir resistance, fluid resistance, surface friction, material deformation energy absorption
- OpposesVelocity (rate of change of displacement)
- Function ofvelocity, \(v\), \(\dot{x}\)
- Stores or Dissipates EnergyDissipates kinetic energy
- Typical Symbol, Unit\(c\), N s/m
- Typical Characteristic\(F = cv\)
- Inertia
- CausesLinear acceleration, rotational acceleration
- OpposesAcceleration (rate of change of velocity)
- Function ofacceleration, \(a\), \(\ddot{x}\)
- Stores or Dissipates EnergyStores kinetic energy
- Typical Symbol, Unit\(m\), kg
- Typical Characteristic\(F = ma\)
Energy Relation
Note how stiffness and inertia stores energy while only damping dissipates energy. These properties result in the effect that energy is usually transferred back and forth between stiffness storage and inertia storage. In between such transfers, energy gets dissipated due to damping. An example is used to highlight this point next.
Motion-Energy Relationship
Consider a ball that is dropped from a height of \(x_0\) and bounced on the ground. It starts with potential energy (P in Figure) because of its height. As it picks up speed the potential energy gets converted to kinetic energy (K). The energy transfer is completed right before it hits the ground.
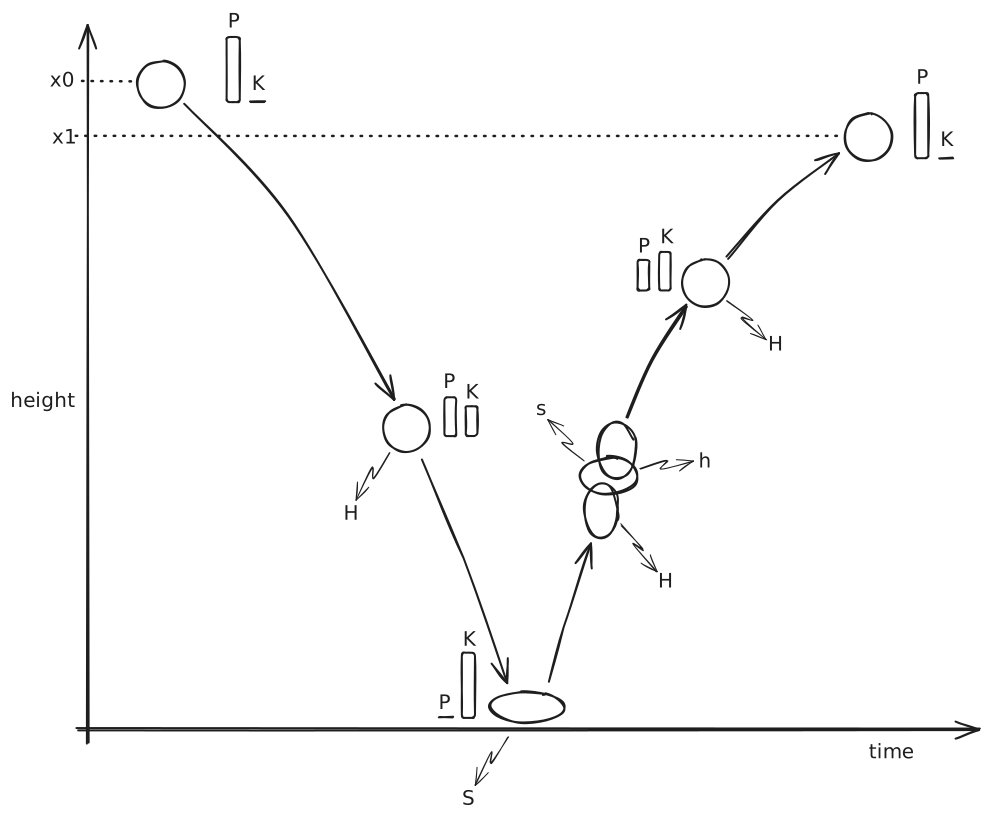
A ball being dropped and bounces. P and K indicate potential and kinetic energy.
Energy is briefly converted back into potential energy again when the ball hits the ground and deforms. It now wants to return to its original shape since all the kinetic energy used to squash the ball is depleted. The ball starts to accelerate back up converting the squash potential energy into kinetic energy and then back into potential as the ball comes to a complete stop at its highest rebound position \(x_1\).
Additional to the potential-kinetic-potential-kinetic-potential energy transfer, energy gets dissipated while moving through the air and other effects. Kinetic energy right before impact is equal to the starting (\(x_0\)) potential energy (ignoring drag energy loss). The highest (at impact) velocity (\(v_{max}\)) can be calculated as:
\[KE = \tfrac{1}{2} m v_{max}^2 \approx m g x_0 = PE\]
\[v_{max} \approx \sqrt{2 g x_0}\]
A drag force of \(F_d = \tfrac{1}{2} C_d \rho A v^2\) would have worked to slow the ball down all the way from \(x_0\) to the floor (from \(v = 0\) to \(v = v_{max}\)).
When the ball hits the floor a new energy conversion branch splits off from the main branch. Steel balls bouncing on steel are 99% elastic, restoring its spherical shape when leaving the floor. Sports balls has a contact time with the floor that is much shorter than the period of the ball’s first natural frequency. This causes it to oscillate between a squished and stretched oval shape while travelling up after impact.
A considerable amount of energy goes into this oscillation that dissipates it into sound energy (S) and heat energy, both outside (H) and inside the rubber (h). Even the floor, if flexible relative to the ball’s dynamics, will also absorb energy and vibrate, dissipating it as sound energy. The vibrating phenomena is possible because of stiffness and inertia and will be seen again in Section.
Combined Effect of Governing Interactions
In nature all three elements work together as energy gets transferred between them. But before we go all out and mix everything up again, let's see how two-two work together.
Stiffness and Damping
Without mass there is no inertia to carry the particle past its mark. The spring decides where the particle wants to come to rest and the damper governs how quickly it gets there. When the force steps up, the position eases smoothly toward its steady offset of \(F/k\); when the force is removed it relaxes back to zero just as smoothly. There is no overshoot and no oscillation — with no kinetic energy store, the motion can only ever approach its target, never pass it (Figure ).
A step-up-down force applied on an object governed by stiffness and damping.
Inertia and Damping
Here there is no spring, so nothing pulls the particle back to where it started. The damper caps how fast it can move and the mass smooths the start and the stop. While the force acts, the particle accelerates and settles into a steady drift; once the force is gone the mass keeps it coasting, but the damper steadily bleeds the velocity away until it glides to a halt — and there it stays, with no restoring force to call it home (Figure ).
A step-up-down force applied on an object governed by inertia and damping.
Stiffness and Inertia
This is where it gets interesting. With this combination the two energy storable and releasable governing interactions, energy can be indefinitely shifted. Just like a pendulum or an idealistic bouncing ball, the spring and mass system will oscillate after perturbation.
A step-up-down force applied on an object governed by stiffness and inertia.
Full System
Add the damper back to the spring and mass of Figure and we have the complete picture — the single equation that governs very nearly everything that moves: \[m\ddot{x} + c\dot{x} + kx = F\] The stored energy still sloshes between spring and mass, but now the damper drains a little of it with every swing. The particle overshoots its steady offset, rings a few times, and settles (Figure ). Remove the force and it rings back down to rest. Stiffness, damping and inertia acting together — every trajectory, every vibration and every impact in the physical world is some version of this one balance.
A step-up-down force applied on an object governed by stiffness, inertia and damping.
Conclusion
There is much more detail to go into when looking at how stiffness and damping forces act on a mass. For example, the motion of the mass can be tuned over damped, under damped or critically damped. The analytic equations of motion can also be derived to calculate the position of the mass as a function of time. Such depth is however easily to find on the internet. This article series will rather move on to exploring the interesting effects of larger interacting systems.
The single degree of freedom (DoF) system is useful for understanding stiffness, mass and damping (SMD) forces on point objects but seldom represents real world scenarios. As hinted to in section 1, even a marble’s atoms move relative to each other with SMD interacting forces. What seemed to be a single point object is actually, like all matter, a continuous multi-DoF SMD system. In the next article on the Beauty of Motion multi-DoF SMD systems will be explored.